Delta Robot
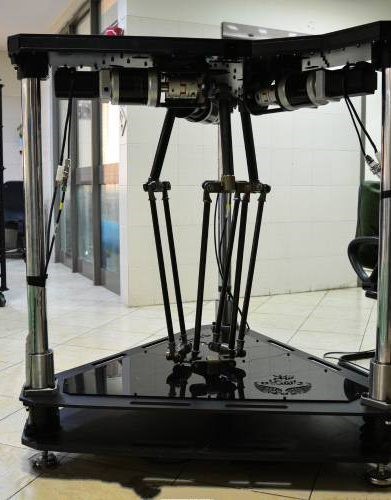
Delta Robot at the Human–Robot Interaction Laboratory, University of Tehran
Design and Construction of a Delta Parallel Robot for High-Speed Pick-and-Place Operations:
The Delta robot is considered one of the most successful and widely used types of parallel robots, with numerous applications worldwide. It was first introduced by Professor Reymond Clavel from EPFL University in Switzerland. The Delta robot is a parallel mechanism with three translational degrees of freedom. Despite having a more limited workspace compared to serial robots, parallel robots offer higher speed, precision, and stiffness. These features make them particularly useful in manufacturing industries such as pharmaceuticals, food processing, and waste recycling, where direct human contact must be avoided.
In recent years, and in response to the demands of industrial companies, the Human–Robot Interaction Laboratory at the University of Tehran has designed and constructed several industrial-scale Delta robot prototypes. The laboratory has also conducted extensive research on other types of parallel robots such as Gough–Stewart platforms and cable-driven robots, achieving significant research outcomes in modeling, control, and optimal design.
Projects:
-
Design of an intelligent controller for cable-driven serial–parallel manipulators with variable configurations
-
Closed-loop control of a 6-DOF pneumatic Gough–Stewart parallel robot
-
Dynamic identification and control of a spatial cable robot for object tracking using image processing
-
Control and dynamic identification of a 3-DOF Tripteron parallel mechanism and development of a human–robot interaction interface
-
Design and construction of a 2-DOF robot for eye–motion interaction using brain signals
-
Singularity analysis of parallel robots with identical kinematic chains using Grassmann–Cayley algebra
-
Determination of singularity-free workspaces for parallel robots using optimization algorithms
-
Development of a virtual dental drilling environment with impedance control implemented on a modified Falcon haptic device
-
Dynamic analysis and identification of over-constrained parallel robots
-
Control of a 6-DOF Gough–Stewart parallel robot based on pneumatic actuator control
-
Optimization of kinematic sensitivity and workspace of planar parallel mechanisms
-
Kinematic optimization and dimensional synthesis of parallel robots
-
System identification and position control of a 3-DOF independent parallel mechanism
-
Kinematic identification and control of a 4-DOF Delta robot
-
Design and fabrication of an artificial skin tactile sensor for safe human–robot interaction in a 3-DOF parallel robot
-
Identification and control of a 3-DOF parallel robot with force sensing for human–robot interaction
-
Dynamic analysis, identification, and control of a 3-DOF Delta parallel robot using base inertial parameters
-
Design of an adaptive controller based on online identification for parallel robot dynamics
-
Use of an agile vision robot for human detection and tracking
-
Control of an underactuated suspended cable robot for 3D visual modeling of objects
-
Control of a 3-DOF Delta parallel robot for pick-and-place operations using machine learning
-
Design and control of a 3-DOF Delta robot using sensor fusion techniques
-
Design, identification, and implementation of a vision-based pick-and-place process for a 3-DOF Delta parallel robot
-
Design and implementation of a control system for a 3-DOF Delta parallel robot using learning-based methods
-
Control of a suspended cable-driven parallel robot for intelligent video recording of football matches and visual data analysis
-
Implementation of liquid pick-and-place operations in test tubes with unknown configurations using a Delta parallel robot and image processing
-
Control of parallel robots based on the dynamic modeling of their kinematic chains using reinforcement deep learning with level-set dynamic programming
Faculty Members:
-
Dr. Mehdi Tale Masouleh
-
Dr. Ahmad Kaleh
-
Dr. Mohammadreza Haeri Yazdi
Collaborating Unit:
-
Human–Robot Interaction Laboratory, University of Tehran
Selected Publications:
- Bahrami, Vahid, Ahmad Kalhor, and Mehdi Tale Masouleh. "Redundancy resolution of a variable base frame of a 3-DoF cable-driven serial chain by using an adaptive neuro-fuzzy controller." Journal of the Franklin Institute 362, no. 1 (2025): 107348.
- Bahrami, Vahid, Mehdi Tale Masouleh, and Ahmad Kalhor. "Developing a reinforcement learning-based actor–critic neural network controller for general form of serial chain robots with torque constraints." Mechanism and Machine Theory 199 (2024): 105676.
- Dastjerdi, Amir Hashemi, Mohammad Morad Sheikhi, and Mehdi Tale Masouleh. "An analytical approach to the stiffness calculation of statically indeterminate 3-DOF delta parallelogram-type parallel robot." Proceedings of the Institution of Mechanical Engineers, Part C: Journal of Mechanical Engineering Science 238, no. 11 (2024): 5142-5158.
- Ghanatian, Mohammad, Mohammad Reza Hairi Yazdi, and Mehdi Tale Masouleh. "Experimental study on controlling suspended cable-driven parallel robots for autonomous video-capturing of football games and obtaining the statistics of the games." Mechatronics 95 (2023): 103058
- Zare, Soroush, Mohammad Reza Hairi Yazdi, Mehdi Tale Masouleh, Dan Zhang, Sahand Ajami, and Amirhossein Afkhami Ardekani. "Experimental study on the control of a suspended cable-driven parallel robot for object tracking purpose." Robotica 40, no. 11 (2022): 3863-3877.
- Tamizi, Mehran Ghafarian, Ali Akbar Ahmadi Kashani, Faraz Abed Azad, Ahmad Kalhor, and Mehdi Tale Masouleh. "Experimental study on a novel simultaneous control and identification of a 3-dof delta robot using model reference adaptive control." European journal of control 67 (2022): 100715.
- Rahimi, Saeed, Hasan Jalali, Mohammad Reza Hairi Yazdi, Ahmad Kalhor, and Mehdi Tale Masouleh. "Design and practical implementation of a Neural Network self-tuned Inverse Dynamic Controller for a 3-DoF Delta parallel robot based on Arc Length Function for smooth trajectory tracking." Mechatronics 84 (2022): 102772.
- Bahrami, Vahid, Ahmad Kalhor, and Mehdi Tale Masouleh. "Dynamic modeling and design of controller for the 2-DoF serial chain actuated by a cable-driven robot based on feedback linearization." Proceedings of the Institution of Mechanical Engineers, Part C: Journal of Mechanical Engineering Science 236, no. 5 (2022): 2546-2558.
- Abed Azad, Faraz, Saeed Ansari Rad, Mohammad Reza Hairi Yazdi, Mehdi Tale Masouleh, and Ahmad Kalhor. "Dynamics analysis, offline–online tuning and identification of base inertia parameters for the 3-DOF Delta parallel robot under insufficient excitations." Meccanica 57, no. 2 (2022): 473-506.
- Rad, Saeed Ansari, Mehran Ghafarian Tamizi, Amin Mirfakhar, Mehdi Tale Masouleh, and Ahmad Kalhor. "Control of a two-DOF parallel robot with unknown parameters using a novel robust adaptive approach." ISA transactions 117 (2021): 70-84.
- Abbasnejad, Ghasem, and Mehdi Tale-Masouleh. "Optimal wrench-closure configuration of spatial reconfigurable cable-driven parallel robots." Proceedings of the Institution of Mechanical Engineers, Part C: Journal of Mechanical Engineering Science 235, no. 19 (2021): 4049-4056.
- Bahrami, Vahid, Ahmad Kalhor, and Mehdi Tale Masouleh. "Dynamic model estimating and designing controller for the 2-DoF planar robot in interaction with cable-driven robot based on adaptive neural network." Journal of Intelligent & Fuzzy Systems 41, no. 1 (2021): 1261-1280.
- Beiranvand, Arman, Ahmad Kalhor, and Mehdi Tale Masouleh. "Modeling, identification and minimum length integral sliding mode control of a 3-DOF cartesian parallel robot by considering virtual flexible links." Mechanism and Machine Theory 157 (2021): 104183.
- Rad, Saeed Ansari, Mehran Ghafarian Tamizi, Mehdi Azmoun, Mehdi Tale Masouleh, and Ahmad Kalhor. "Experimental study on robust adaptive control with insufficient excitation of a 3-DOF spherical parallel robot for stabilization purposes." Mechanism and Machine Theory 153 (2020): 104026.
- Dastjerdi, Amir Hashemi, Mohammad Morad Sheikhi, and Mehdi Tale Masouleh. "A complete analytical solution for the dimensional synthesis of 3-DOF delta parallel robot for a prescribed workspace." Mechanism and Machine Theory 153 (2020): 103991.
- Hamed, Amin, Mehdi Tale Masouleh, and Ahmad Kalhor. "Design & characterization of a bio-inspired 3-DOF Tactile/Force sensor and implementation on a 3-DOF decoupled parallel mechanism for human-robot interaction purposes." Mechatronics 66 (2020): 102325.
- Zarei, Mojtaba, Navid Kashi, Ahmad Kalhor, and Mehdi Tale Masouleh. "Experimental study on shared-control of a mobile robot via a haptic device with an optimal velocity obstacle based receding horizon control approach." Journal of Intelligent & Robotic Systems 97, no. 2 (2020): 357-372.
- Zarei, Mojtaba, Ahmad Kalhor, and Mehdi Tale Masouleh. "An experimental oscillation damping impedance control for the novint falcon haptic device based on the phase trajectory length function concept." Proceedings of the Institution of Mechanical Engineers, Part C: Journal of Mechanical Engineering Science 233, no. 8 (2019): 2663-2672.
- Heydarzadeh, Mohsen, Nima Karbasizadeh, Mehdi Tale Masouleh, and Ahmad Kalhor. "Experimental kinematic identification and position control of a 3-DOF decoupled parallel robot." Proceedings of the Institution of Mechanical Engineers, Part C: Journal of Mechanical Engineering Science 233, no. 5 (2019): 1841-1855.
- Lafmejani, Amir Salimi, Mehdi Tale Masouleh, and Ahmad Kalhor. "Trajectory tracking control of a pneumatically actuated 6-DOF Gough–Stewart parallel robot using Backstepping-Sliding Mode controller and geometry-based quasi forward kinematic method." Robotics and Computer-Integrated Manufacturing 54 (2018): 96-114.
- Mehrafrooz, Behzad, Mohsen Mohammadi, and Mehdi Tale Masouleh. "A statistical weighted method for kinematic sensitivity analysis of parallel robots: A comprehensive comparison of conventional methods and an improved method." Journal of the Brazilian Society of Mechanical Sciences and Engineering 40 (2018): 1-11.
- Zarei, Mojtaba, Ali Aflakian, Ahmad Kalhor, and Mehdi Tale Masouleh. "Oscillation damping of nonlinear control systems based on the phase trajectory length concept: An experimental case study on a cable-driven parallel robot." Mechanism and Machine Theory 126 (2018): 377-396.
- Karbasizadeh, Nima, Mojtaba Zarei, Ali Aflakian, Mehdi Tale Masouleh, and Ahmad Kalhor. "Experimental dynamic identification and model feed-forward control of Novint Falcon haptic device." Mechatronics 51 (2018): 19-30.
- Safaryazdi, Alireza, Mojtaba Zarei, Omid Abolghasemi, and Mehdi Tale Masouleh. "Experimental study on the model-based control of a 2-degree-of-freedom spherical parallel robot camera stabilizer based on multi-thread programming concept." Proceedings of the Institution of Mechanical Engineers, Part C: Journal of Mechanical Engineering Science 232, no. 10 (2018): 1882-1897.
- Aflakian, Ali, Alireza Safaryazdi, Mehdi Tale Masouleh, and Ahmad Kalhor. "Experimental study on the kinematic control of a cable suspended parallel robot for object tracking purpose." Mechatronics 50 (2018): 160-176.
- Sharifzadeh, Mohammad, Mehdi Tale Masouleh, Ahmad Kalhor, and Pourya Shahverdi. "An experimental dynamic identification & control of an overconstrained 3-DOF parallel mechanism in presence of variable friction and feedback delay." Robotics and autonomous systems 102 (2018): 27-43.
- Danaei, Behzad, Alaleh Arian, Mehdi Tale Masouleh, and Ahmad Kalhor. "Dynamic modeling and base inertial parameters determination of a 2-DOF spherical parallel mechanism." Multibody System Dynamics 41 (2017): 367-390.
- Sharifzadeh, Mohammad, Alaleh Arian, Amir Salimi, Mehdi Tale Masouleh, and Ahmad Kalhor. "An experimental study on the direct & indirect dynamic identification of an over-constrained 3-DOF decoupled parallel mechanism." Mechanism and Machine Theory 116 (2017): 178-202.
- FarzanehKaloorazi, MohammadHadi, Mehdi Tale Masouleh, and Stéphane Caro. "Collision-free workspace of parallel mechanisms based on an interval analysis approach." Robotica 35, no. 8 (2017): 1747-1760.
- Danaei, Behzad, Nima Karbasizadeh, and Mehdi Tale Masouleh. "A general approach on collision-free workspace determination via triangle-to-triangle intersection test." Robotics and Computer-Integrated Manufacturing 44 (2017): 230-241.
- Sharifzadeh, Mohammad, Mehdi Tale Masouleh, and Ahmad Kalhor. "On human–robot interaction of a 3-DOF decoupled parallel mechanism based on the design and construction of a novel and low-cost 3-DOF force sensor." Meccanica 52 (2017): 2471-2489.
- Naderi, Davood, Mehdi Tale-Masouleh, and Payam Varshovi-Jaghargh. "Gröbner basis and resultant method for the forward displacement of 3-DoF planar parallel manipulators in seven-dimensional kinematic space." Robotica 34, no. 11 (2016): 2610-2628.
- Daneshmand, Morteza, Mohammad Hossein Saadatzi, Mohammad Hadi Farzaneh Kaloorazi, Mehdi Tale Masouleh, and Gholamreza Anbarjafari. "Optimal design of a spherical parallel manipulator based on kinetostatic performance using evolutionary techniques." Journal of Mechanical Science and Technology 30 (2016): 1323-1331.
- Sabbagh Novin, Roya, Mehdi Tale Masouleh, and Mojtaba Yazdani. "Optimal motion planning of redundant planar serial robots using a synergy-based approach of convex optimization, disjunctive programming and receding horizon." Proceedings of the Institution of Mechanical Engineers, Part I: Journal of Systems and Control Engineering 230, no. 3 (2016): 211-221.
- Bayani, Hassan, Mehdi Tale Masouleh, and Ahmad Kalhor. "An experimental study on the vision-based control and identification of planar cable-driven parallel robots." Robotics and Autonomous Systems 75 (2016): 187-202.
- Kaloorazi, Mohammad Hadi Farzaneh, Mehdi Tale Masouleh, and Stéphane Caro. "Determining the maximal singularity-free circle or sphere of parallel mechanisms using interval analysis." Robotica 34, no. 1 (2016): 135-149.
- Kaloorazi, Mohammad-Hadi Farzaneh, Mehdi Tale Masouleh, and Stéphane Caro. "Determination of the maximal singularity-free workspace of 3-DOF parallel mechanisms with a constructive geometric approach." Mechanism and Machine Theory 84 (2015): 25-36.
- Karimi, Amirhossein, Mehdi Tale Masouleh, and Philippe Cardou. "Singularity-free workspace analysis of general 6-UPS parallel mechanisms via convex optimization." Mechanism and Machine Theory 80 (2014): 17-34.
Results:
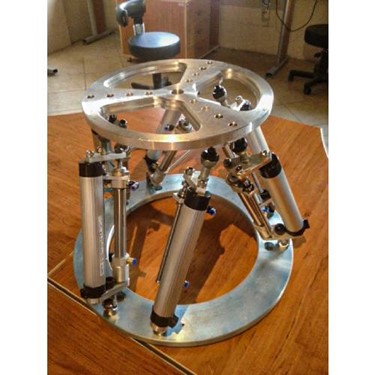
Overview of the Gough–Stewart Robot at the Human–Robot Interaction Laboratory, University of Tehran
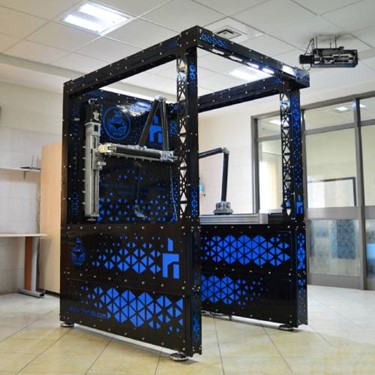
Tripteron Robot at the Human–Robot Interaction Laboratory, University of Tehran
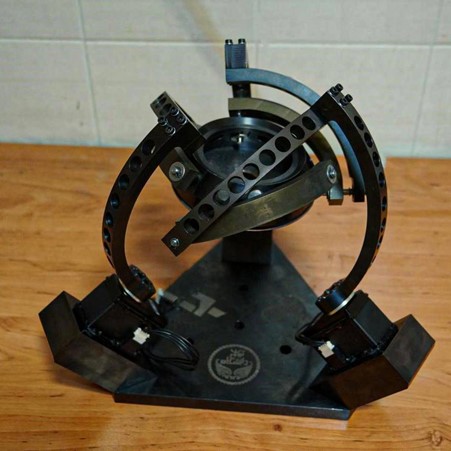
Agile Eye 3-DOF Robot at the Human–Robot Interaction Laboratory, University of Tehran